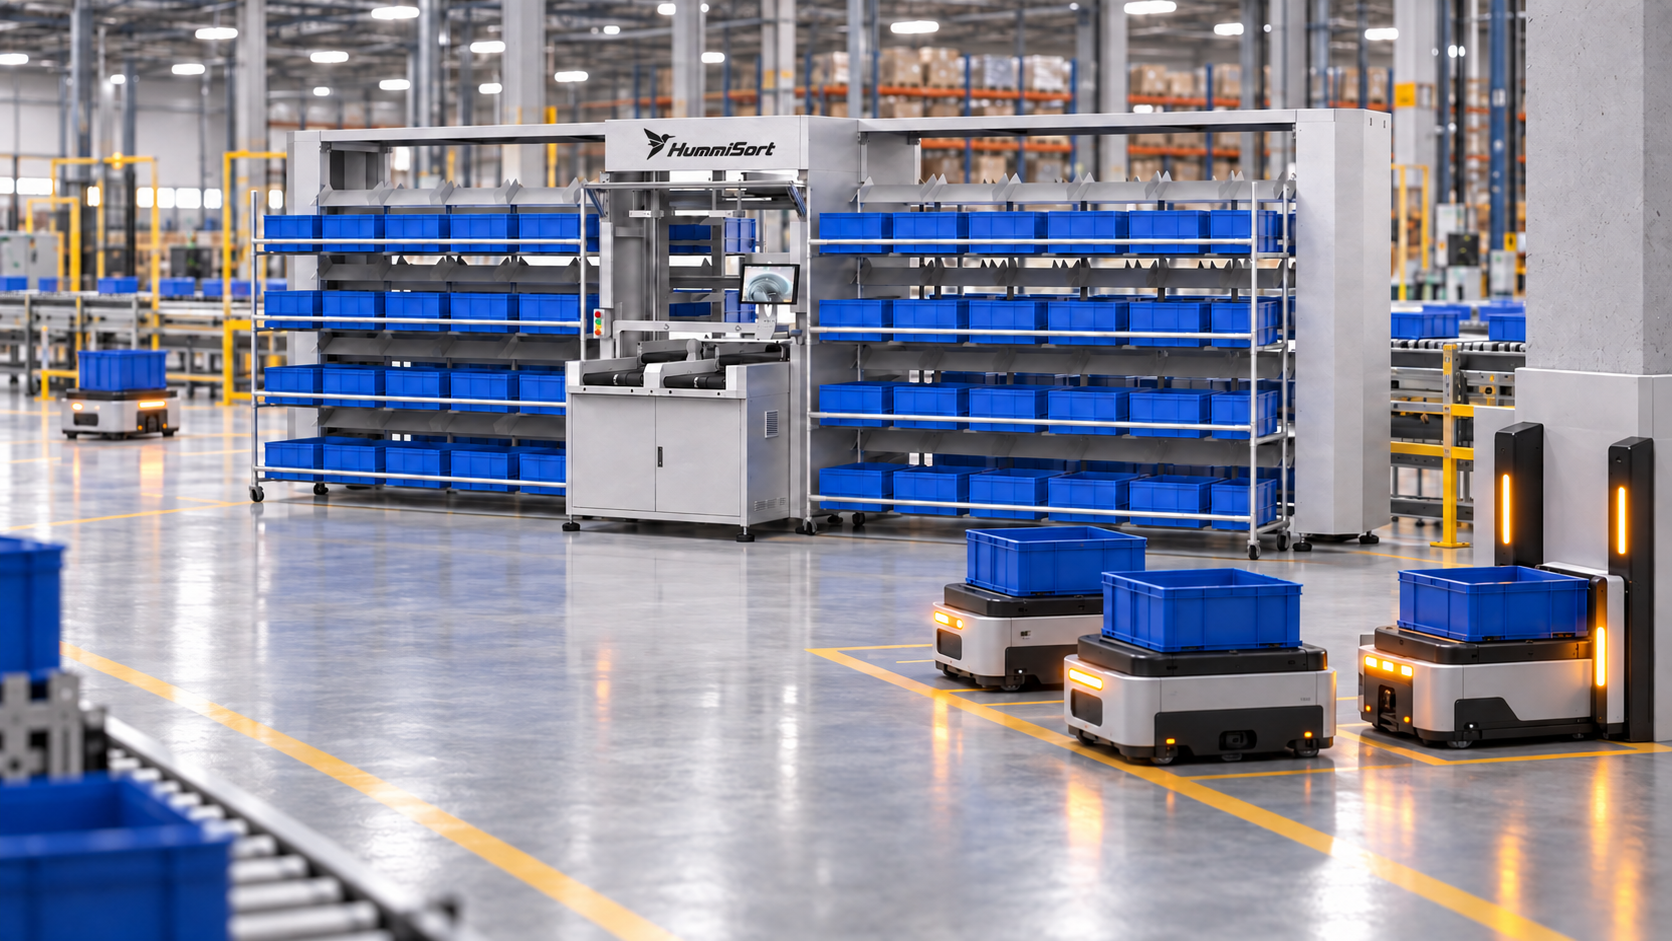
Robot speed becomes irrelevant when the fleet is waiting to charge.
Most automation proposals highlight travel speed, payload and missions per hour. Fewer show what happens when several robots reach a low state of charge during the same peak window.
Then the hidden queue appears:
- travel time to the charger
- waiting for an available dock
- charging time
- returning to the work area
- missions reassigned while the robot is offline
A fleet can look fully available on the dashboard and still lose capacity through synchronized charging.
For downstream operations, the cause does not matter. A put wall waiting for an upstream tote is still waiting—whether the delay came from picking, traffic congestion or a charging queue.
Charging therefore needs to be modeled as part of material flow, not added after the robot count has been decided. Charger locations, opportunity charging, battery thresholds, spare-unit strategy and peak mission patterns all affect real throughput.
Top speed is a specification.
Peak-shift availability is an operating result.
When evaluating a robot fleet, do you measure the fastest possible cycle—or the number of robots actually working during the busiest hour?